Personal Website
H.J. Terry Suh 서형주Hyung Ju Terry Suh
I’m the co-founder and CTO of CarbonSix, where we build Physical AI for manufacturing. I work on giving robots human-like dexterity, and did my Ph.D. at MIT CSAIL.
terry.suh at carbon6robotics dot com
Introduction
CarbonSix
I co-founded CarbonSix in 2024, where I am the CTO and lead R&D on SigmaKit, the world’s first industrial imitation learning kit for manufacturing.
Awards
Inaugural IJRR Paper of the Season 2026
IEEE T-RO King-Sun Fu Memorial Best Paper Award, Honorable Mention 2023
ICML Outstanding Paper Award 2022
IEEE RAS TC on Model-Based Optimization for Robotics, Best Paper Award 2022
Research interest
I work on giving robots human-like dexterity in manipulation. My research focuses on efficient Physical AI, combining model-based tools with robot learning to achieve robust performance in the small-data regime.
Academics
- MIT CSAIL2019 – 2024Ph.D. · Advisor: Russ Tedrake
- Caltech2013 – 2019B.S., Mechanical Engineering and Computer Science
- Korean Minjok Leadership Academy2010 – 2012High School
Industry
- CarbonSix2024 – nowCo-Founder & CTO
- The Robotics and AI Institute2023Researcher
- Toyota Research Institute2021Researcher
- NASA JPL2017 – 2018Researcher
Recent Events
- CarbonSix raised a $40M Series A to deploy Physical AI across global manufacturing.
- Our paper on the contact trust region received the inaugural IJRR Paper of the Season award (news).
- We launched SigmaKit, a standardized robot imitation learning toolkit for manufacturing.
- I co-organized the Workshop on Learning Meets Model-Based Methods for Contact-Rich Manipulation at ICRA 2025.
- I co-founded CarbonSix, where I am the CTO.
- I defended my Ph.D. thesis at MIT: Leveraging Structure for Efficient and Dexterous Contact-Rich Manipulation.
Show 11 earlier eventsShow fewer
- Our Transactions on Robotics paper got Honorable Mention for 2023 T-RO King-Sun Fu Memorial Best Paper Award of the Year.
- Check out my interview with CSAIL Alliance!
- I am hosting a Workshop on Leveraging Models for Contact-Rich Manipulation at IROS 2023 with colleagues.
- I am organizing the MIT Embodied Intelligence Seminar.
- Our work on contact-rich manipulation is on MIT News!
- Our ICML paper got the IEEE RAS TC on Model-Based Optimization for Robotics 2022 Best Paper Award of the Year.
- Our work on Series Elastic End Effectors is on MIT News!
- Our paper on differentiable simulators got Outstanding Paper Award at ICML 2022! See my talk here!
- I am TAing a class on Robotic Manipulation this term (MIT 6.881).
- I am doing an internship at Toyota Research Institute: Robotics for the summer in the manipulation team, with Naveen Kuppuswamy.
CarbonSix
CarbonSix builds Physical AI for manufacturing, aimed at the high-variance work that conventional robots leave to people: deformable parts, thin films, swinging hooks. Our product, SigmaKit, combines AI software with robotic hands, teaching devices and sensor modules. An operator demonstrates a task and the robot learns it as a skill, with no coding or AI expertise required. These clips run autonomously at 1x speed.
Academic Research
Leveraging Structure for Efficient and Dexterous Contact-Rich Manipulation
MIT Thesis, Ph.D. degree, 2025
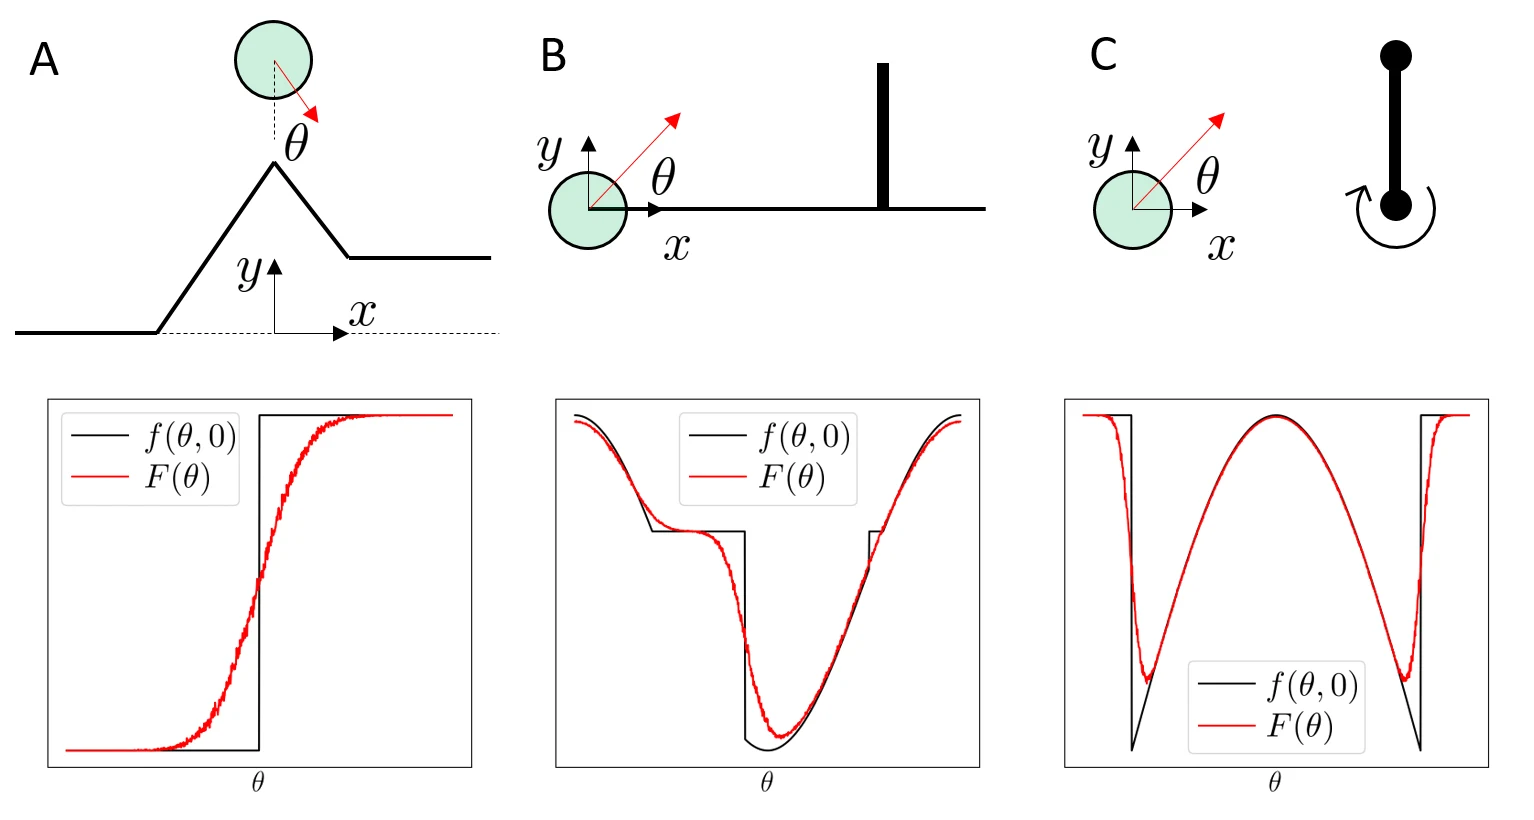
Do Differentiable Simulators Give Better Policy Gradients?
2022 International Conference on Machine Learning (ICML)
ICML Outstanding Paper Award
IEEE RAS TC on Model-based Optimization for Robotics 2022 Best Paper Award of the Year
Pathologies and Challenges of Using Differentiable Simulators in Policy Optimization for Contact-Rich Manipulation
ICRA 2022 Workshop: Reinforcement Learning for Contact-Rich Manipulation
SEED: Series Elastic End-Effectors in 6D For Visuotactile Tool Use
SEED: Series Elastic End-Effectors in 6D For Compliant Visuotactile Tool Use
2022 ICRA Workshop: Compliant Robot Manipulation: Challenges and New Opportunities
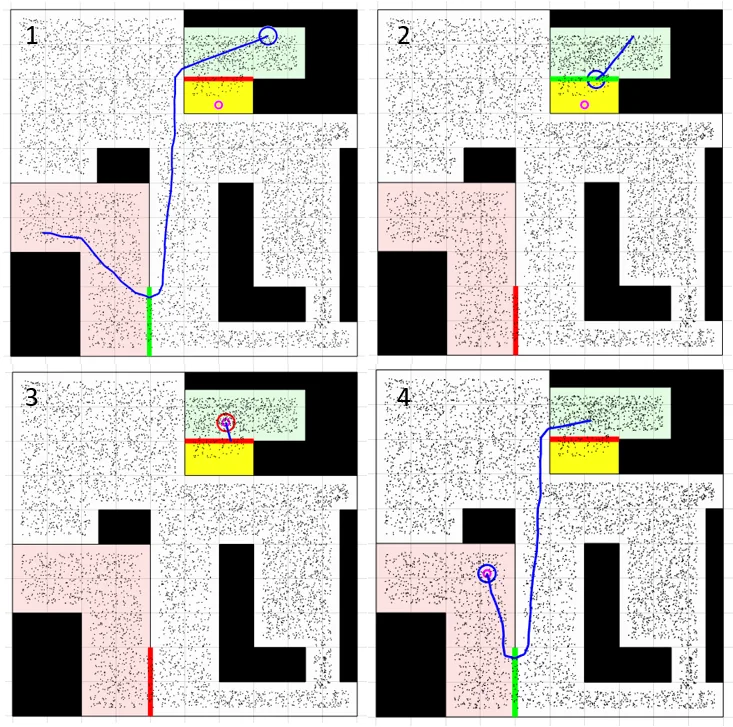
Semantic Task Planning with Temporal Logic Synthesis
Semantic Task Planning in Household Environments using Temporal Logic Synthesis
Self-hosted, 2018
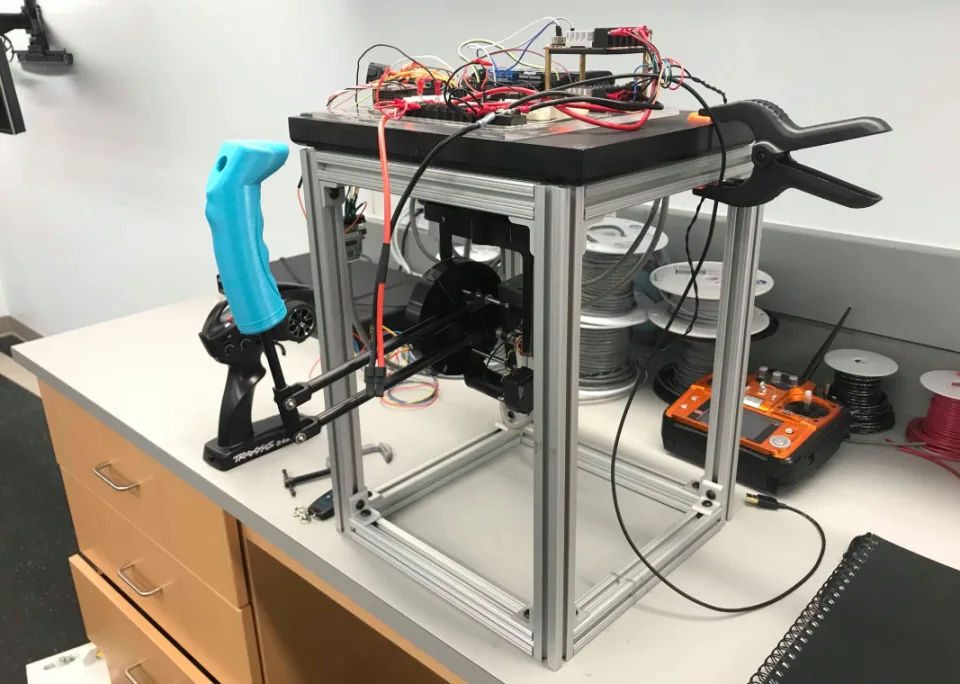
Vehicle Teleop with Impedance Controlled Manipulator
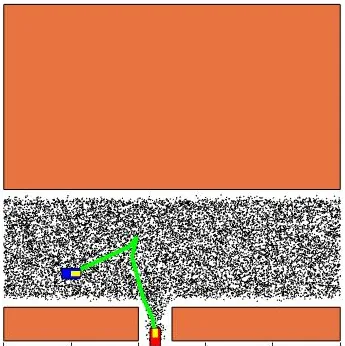
Fast Path Planner for Car-like Nonholonomic Vehicles
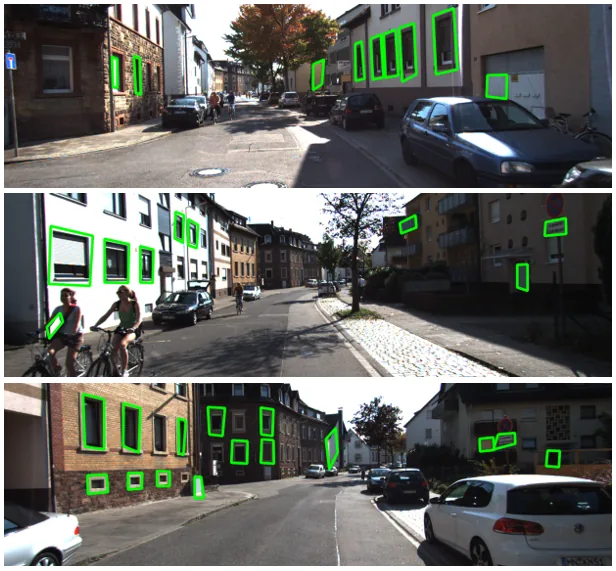
Visual-Inertial SLAM with High-Dimensional Features
Inertial-aided Normal Estimation for Planar Feature Mapping: Unique Solutions to Homography Decomposition
Self-hosted, 2018
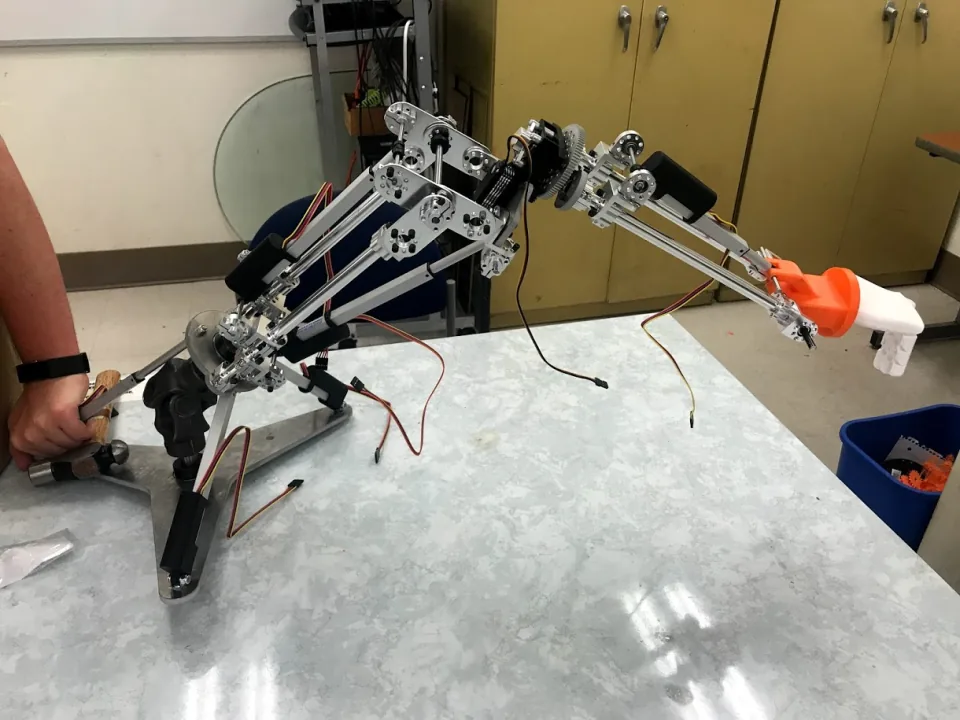
Design of an Anthropomorphic Arm with Linear Actuators
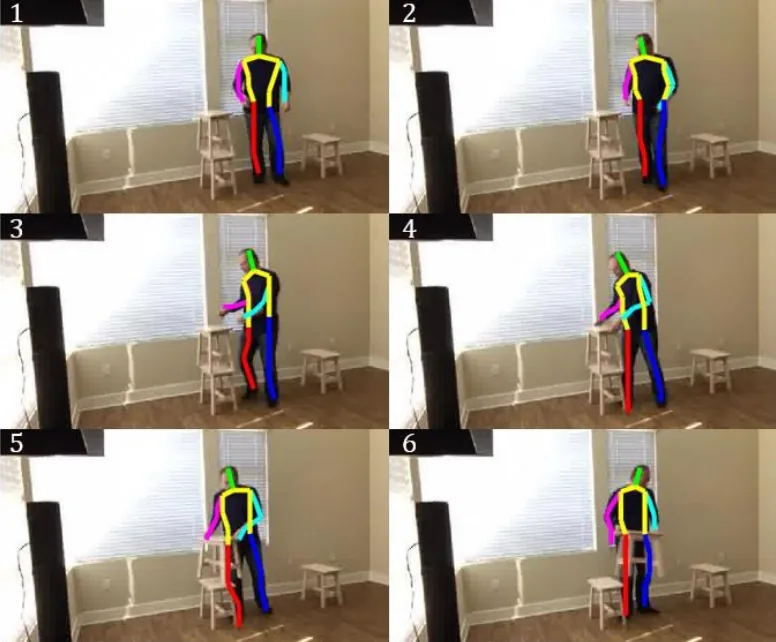
Humanoid-Oriented Movement Writing
Towards a Humanoid-Oriented Movement Writing
2017 IEEE International Conference on Systems, Man, and Cybernetics (SMC)
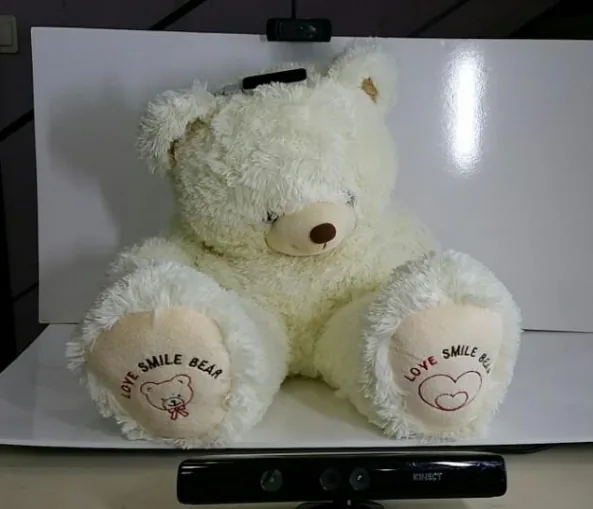
Intelligent Bear Robot that Learns Emotions
Design of an Intelligent Bear Robot with Emotional Learning Capabilities for Enhanced Human-robot Interaction
Self-hosted, 2014
My Robots
A few people have the pleasure of designing an entire robot from scratch. It takes long hours and incredible effort to build one, but the joy of seeing it move and perform is quite incomparable to anything else. When you design and make a robot, you create some form of life; and no matter how primitive it is, you are its creator. I always imagine its blood pumping through the red and black power wires, and its brain running basic thoughts in a metal computer.
The robots I made and designed have a very special place in my heart, for I am like their father.
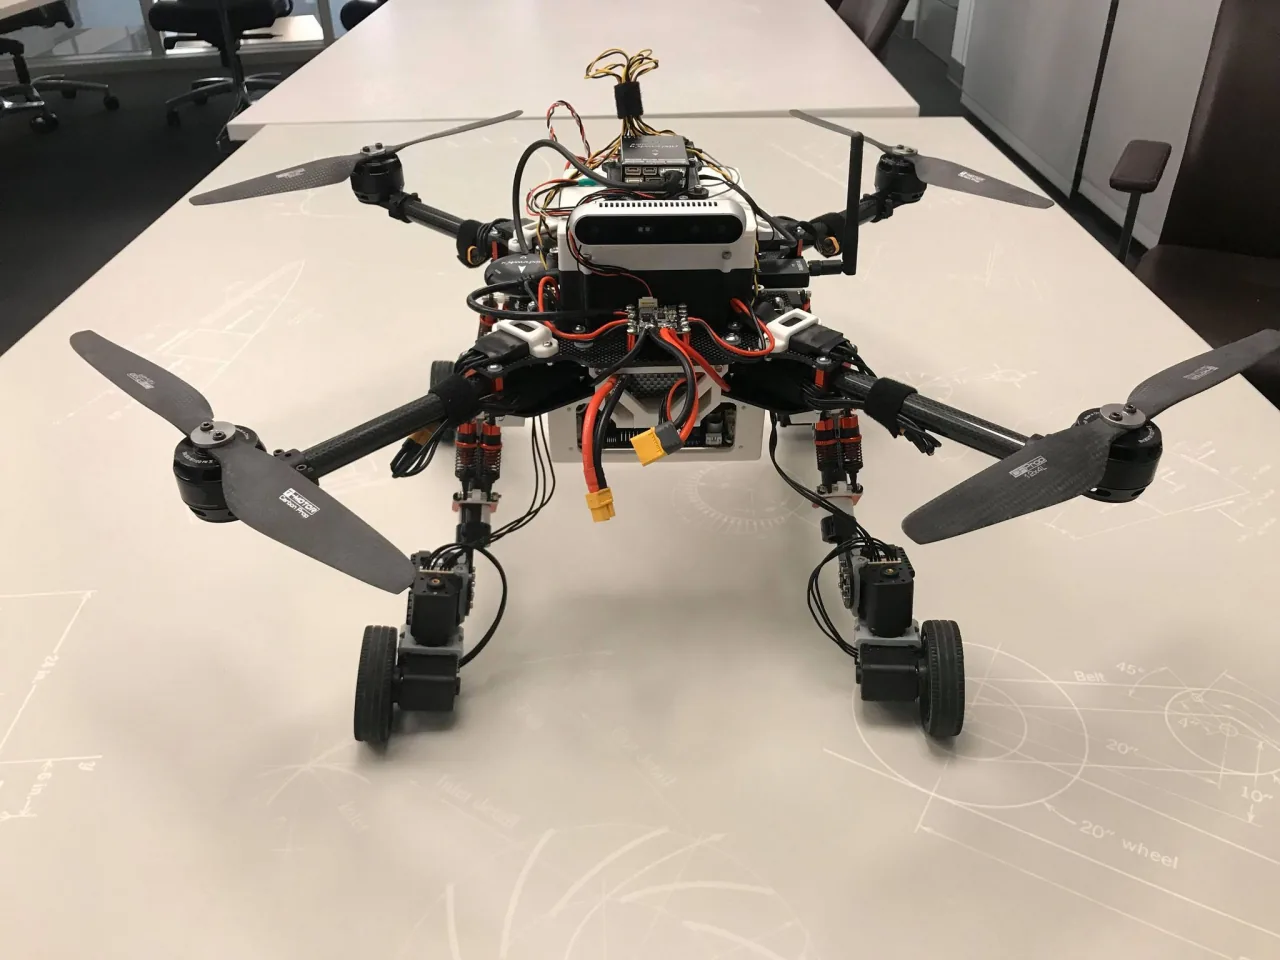
The Drivocopter
The Drivocopter was a hardware platform I built for my undergraduate thesis, funded by JPL / Caltech team’s entry in DARPA’s Subterranean challenge. It is a robot that is designed to have both driving and flying capabilities. It’s the biggest hardware project that took a year for me and the Caltech ME/EE/CS75 team to design, build, iterate, and test under guidance from Prof. Joel Burdick.
It survived many interesting crashes. I accidentally drove it into a pond one time, and a bad landing maneuver once broke all of its legs.
Here are some cool videos of the Drivocopter!
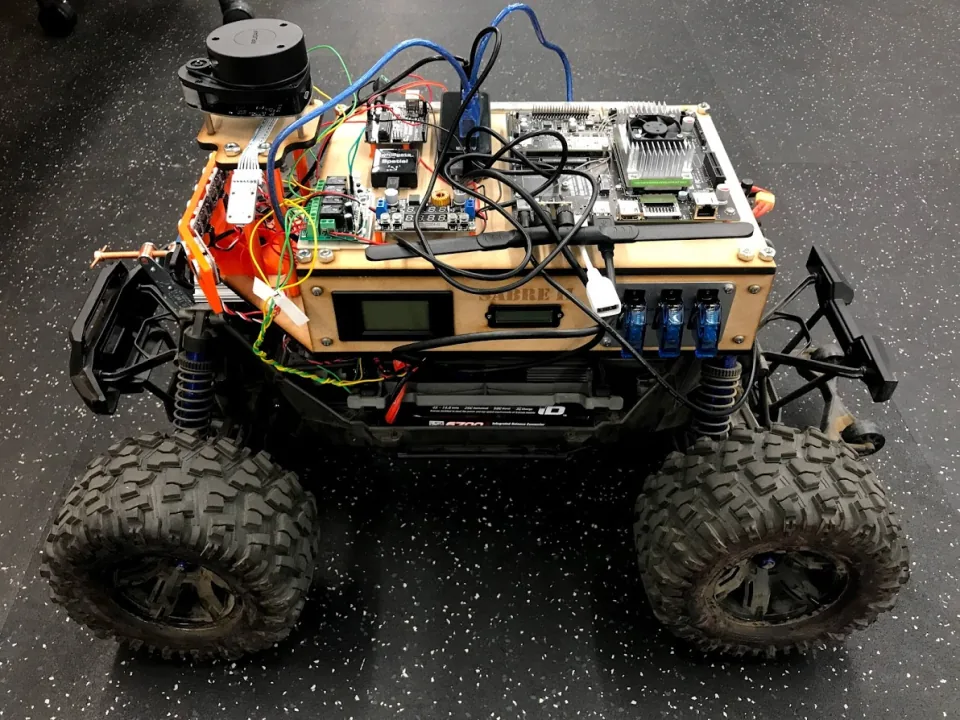
Saber II: Offroad Autonomous Driving Platform
Saber was an off-road reconnaissance robot that a team of researchers at JPL were building with Dr. Adrian Stoica as the lead. Unfortunately, we didn’t get to finish the project due to couple hiccups right before the deadline.
I took my favorite RC car and rebooted the concept to make Saber II (though it’s missing many expensive sensors as this was a self-funded project). It uses the Traxxas X-Maxx chassis, and has an NVidia TX-2 as the central computer.
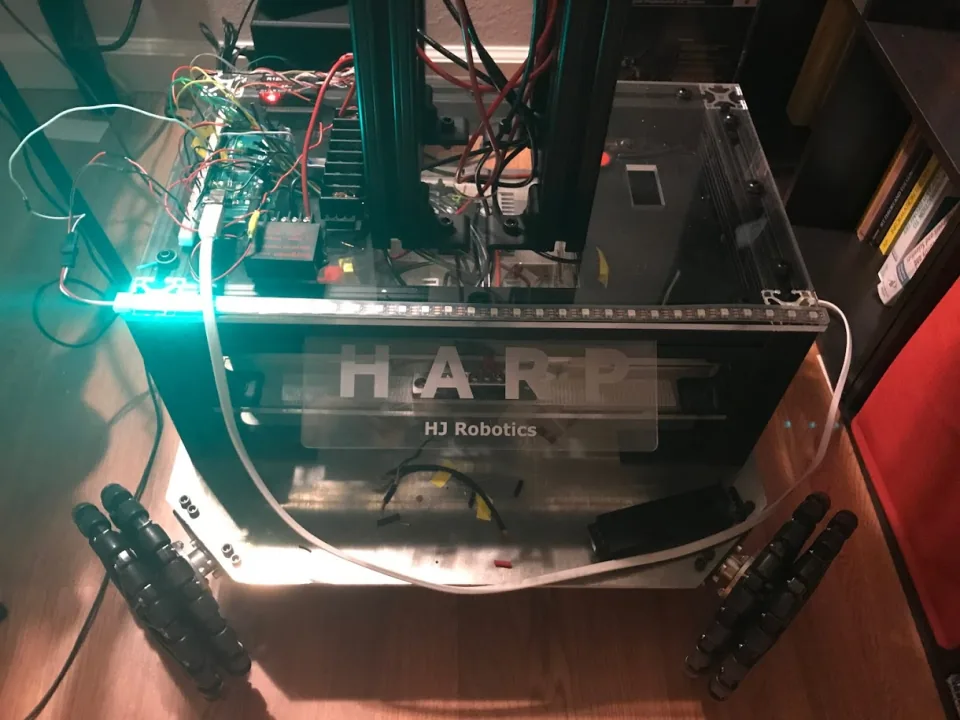
HARP: Home Autonomous Robotic Platform
HARP was my experiment with building a mobile platform for home robots. I never built anything of this scale (full-human size) before, so there were many interesting design (and cost!) challenges there.
Although I was never able to finish HARP, I have a video of its brief operation.
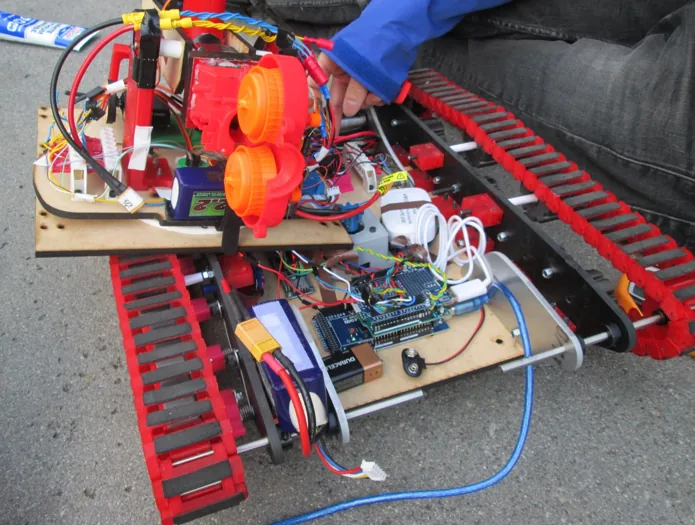
The Ring of Fire: Drogon, Rhaegal, and Viserion
These skid-steer tank robots were built as a part of Caltech’s ME72, a mechanical engineering capstone course taught by Dr. Michael Mello. Our team name was “Ring of Fire”, with members Cormac O’Neill (later a fellow grad student at MIT!), James Deacon, and Hana Keller. I was watching Game of Thrones at the time, which explains the robot names (there were three identical ones).
This is when I started to seriously delve into mechanical design, and remember spending many all-nighters trying to fix tons of failure modes. I’ll never forget the night I was pulling off an all nighter with Cormac to work on one of these robots, and one of the on-board regulators suddenly blew up in a puff of unhealthy-smelling smoke!
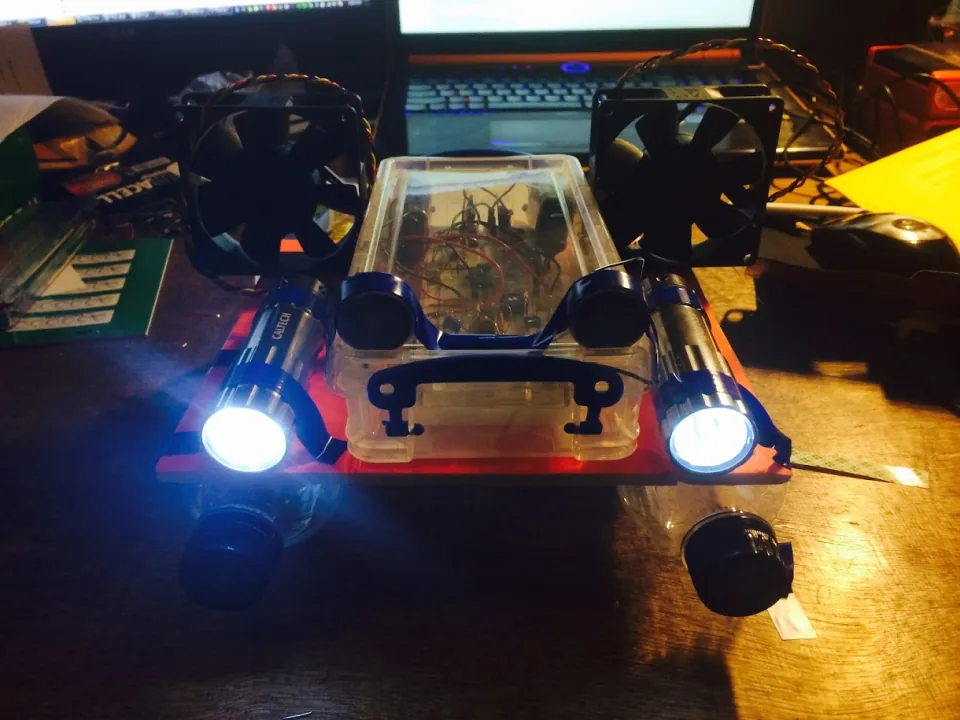
Ultrasound Tracking Fanboat
This boat was a small electronics project I built for Caltech’s ME/EE 7: Introduction to Mechatronics course. It uses an analog PID circuit to track an ultrasound signal. One might say it’s the first robot I ever made.
Music
I am an amateur singer-songwriter. I write, record, and mix songs as a hobby, and play a lot of instruments (guitar, piano, bass, drums, harmonica, flute, etc.)
If you’re interested, check out my Soundcloud Page! (Though the last serious recording I made was in 2016)